UAV-Based Maritime Object Tracking: A New Data Set and Dynamic Multi-scale Fusion Transformer
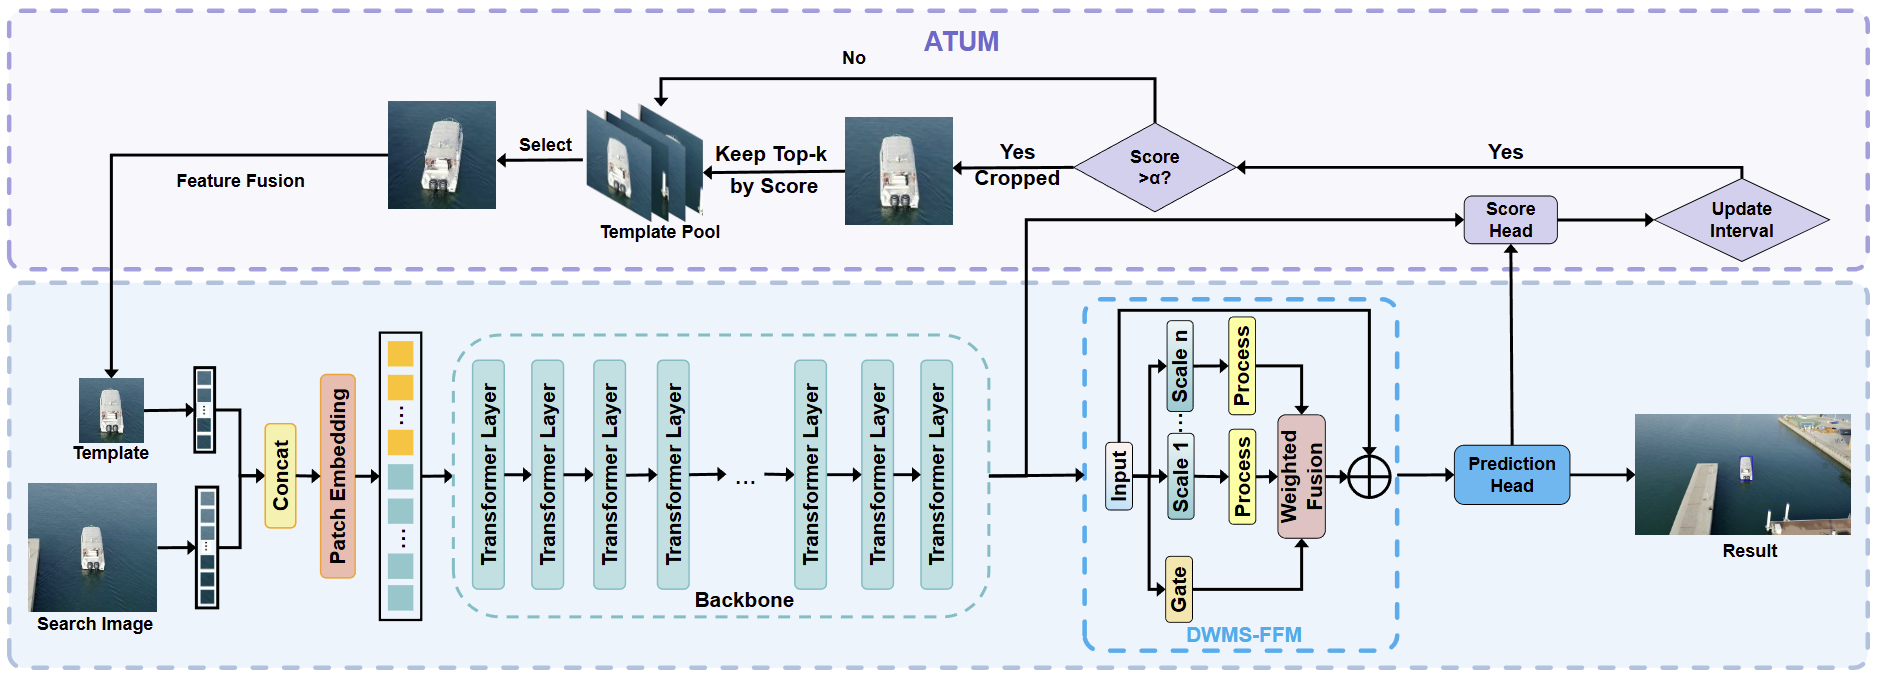

The architecture of the proposed DMFTrack.

Abstract
To perform the Unmanned Aerial Vehicle-based (UAV-based) maritime object tracking task, we acquire a new ship tracking data set, namely, UAVSeaShip102. This task faces severe challenges due to rapid target motion, drastic scale variations, and frequent occlusion in complex aerial scenes. Recent transformer-based trackers have shown remarkable potential in modeling long- range dependencies. However, their performance often deteriorates when faced with large-scale changes or unreliable updates. To address these issues, we propose a Dynamic Multi-scale Fusion Transformer Tracker (DMFTrack) for UAV-based single object tracking, which comprises two key components, i.e., a Dynamically-Weighted Multi-scale Feature Fusion Module (DWMS- FFM) and an Adaptive Template Update Mechanism (ATUM). The DWMS-FFM adaptively aggregates features from multiple scales via a learnable gating strategy, allowing the model to dynamically balance spatial details and global context. Furthermore, the ATUM employs a Score Head to estimate the reliability of the current template through dual-stage cross-attention, allow- ing confidence-guided online template updates that mitigate model drift. Extensive experiments conducted on UAVSeaShip102 and five commonly-used UAV-based benchmarks demonstrate that our method outperforms 22 trackers in challenging scenarios, which involve scale variation, occlusion, and background clutter, while maintaining real-time performance. It is suggested that DMFTrack is also applicable to other aerial tracking scenarios.
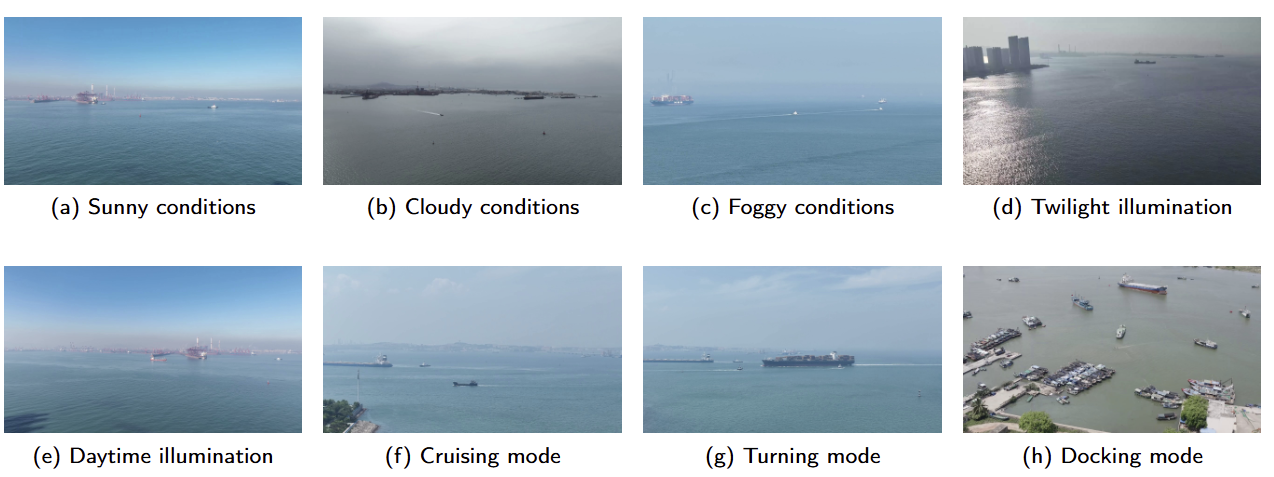
Dataset Display

Eight sequence examples contained in UAVSeaShip102, captured under different weather conditions, illuminations and motion patterns.
Experimental Results

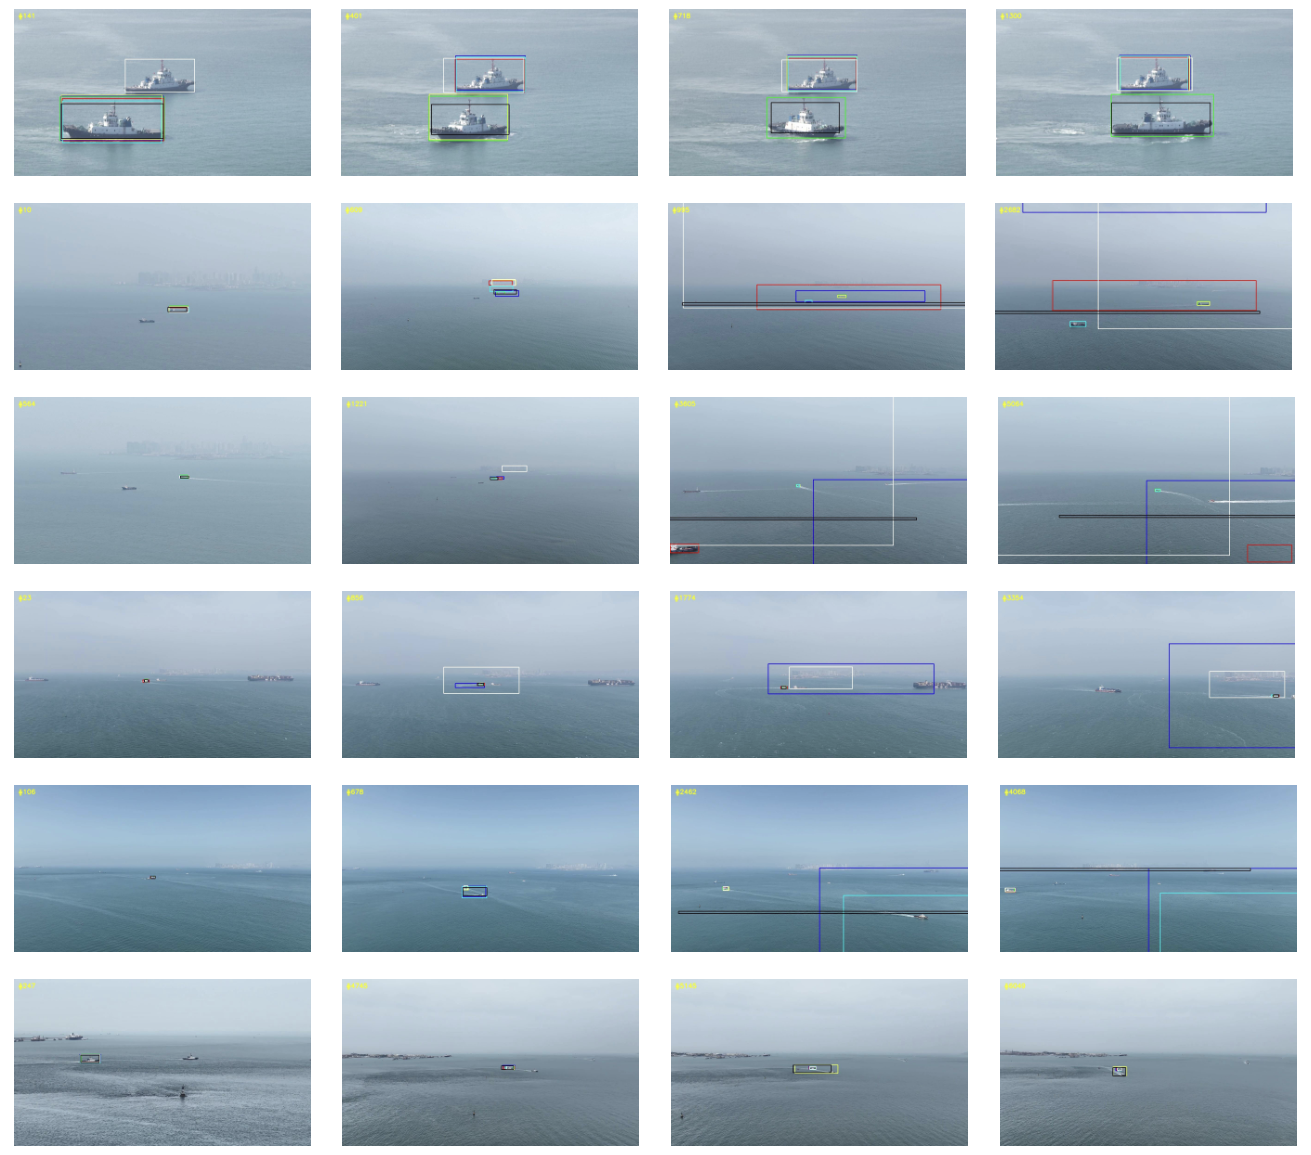
Visualization of the results of our tracker and six state-of-the-art baselines on six challenging sequences contained in our UAVSeaShip102 data set, including Ship0010, Ship0029, Ship0030, Ship0034, Ship0035 and Ship0043 (from top to bottom).
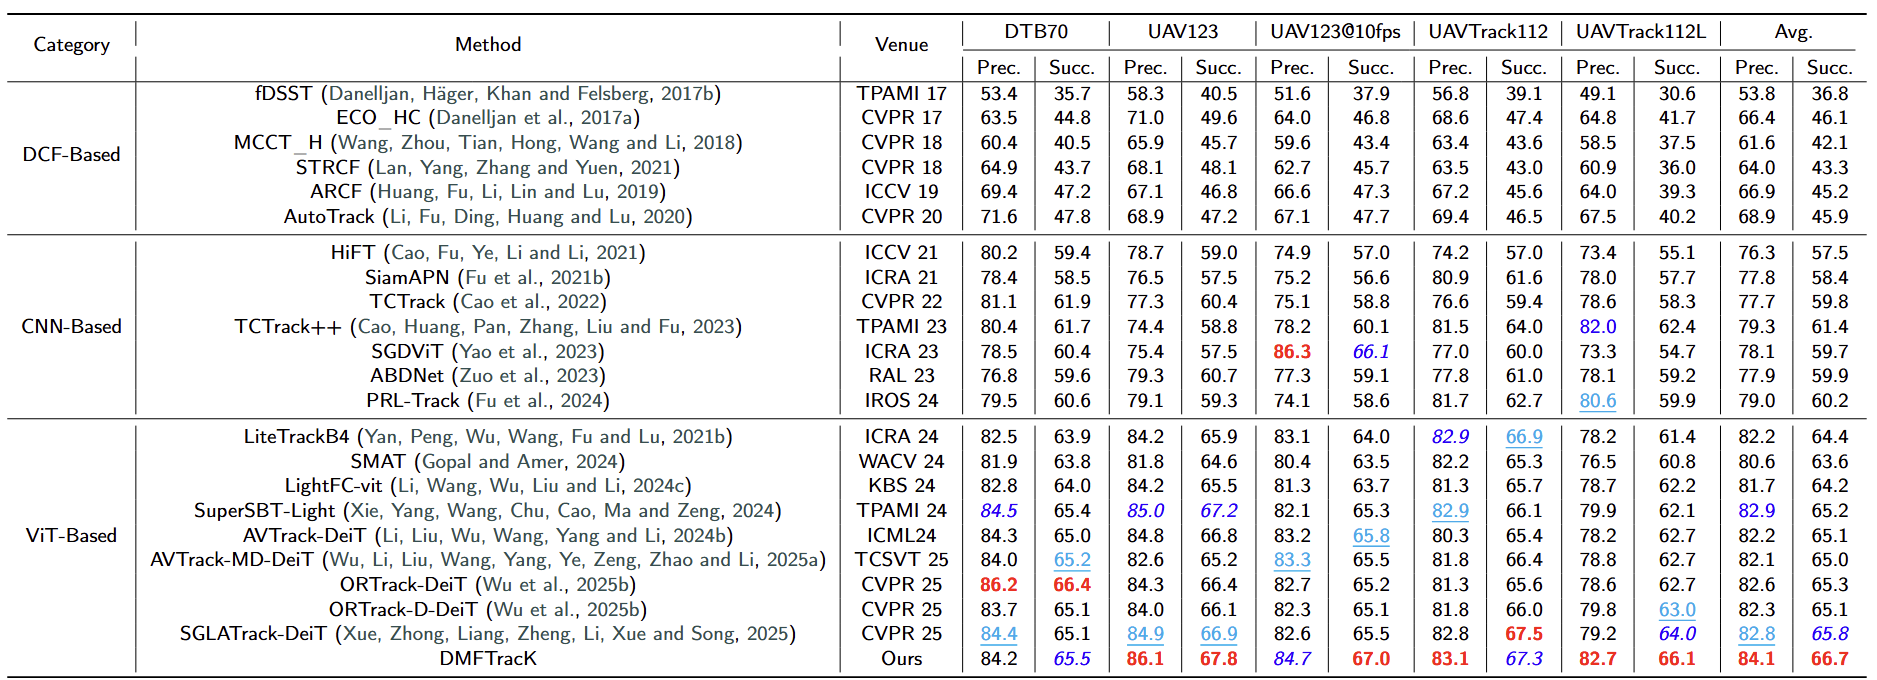

Comparison between our method and 22 state-of-the-art lightweight trackers in terms of the precision and Success Rate metrics on the test sets of DTB70, UAV123, UAV123@10fps, UAVTrack112 and UAVTrack112L. In addition, the average metric values computed across the five data sets are presented in the column of “Avg.”. Here, the top three results derived in each case are highlighted in the red, blue and cyan fonts, respectively.

Citation
                    
                @article{,
                title={UAV-Based Maritime Object Tracking: A New Data Set and Dynamic Multi-scale Fusion Transformer},
                author={Xinyue Wang, Jingjing Xiao, Xinghui Dong},
                journal={Ocean Engineering},
                doi = {https://doi.org/10.1016/j.oceaneng.2026.129158},
                year={2026}
                }